

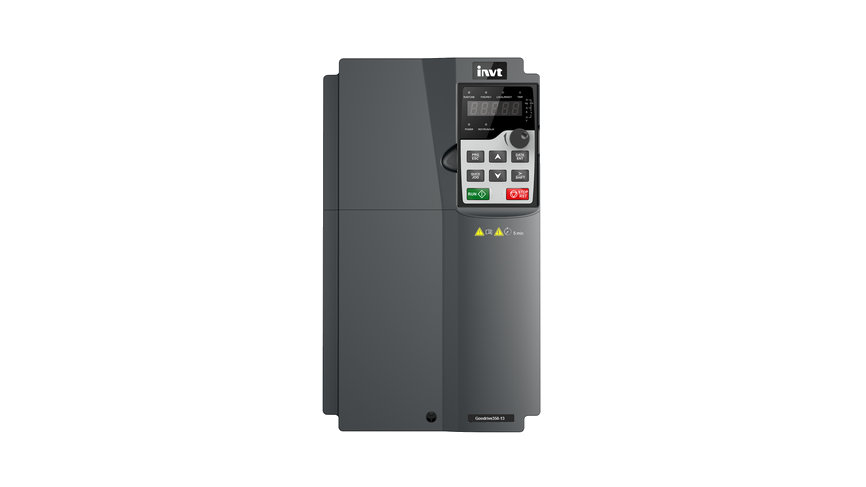


Item | Specifications | |
Power input | Input voltage (V) | AC 3PH 380V (-15%)–440V(+10%); rated voltage: 380V AC 3PH 520V (-15%)–690V (+10%); rated voltage: 660V |
Input frequency (Hz) | 50Hz or 60Hz; allowed range: 47–63Hz | |
Power output | Output voltage (V) | 0–input voltage |
Output frequency (Hz) | 0–400Hz | |
Technical control performance | Control mode | Space voltage vector control, sensorless vector control (SVC), and feedback vector control (FVC) mode |
Motor type | Asynchronous motor (AM) and permanent magnet synchronous motor (SM) | |
Speed ratio | AM: 1:200 (SVC) SM: 1:20 (SVC), 1:1000 (FVC) | |
Speed control accuracy | ±0.2% (SVC), ±0.02% (FVC) | |
Speed fluctuation | ±0.3% (SVC) | |
Torque response | <20ms (SVC), <10ms (FVC) | |
Torque control accuracy | 10% (SVC), 5% (FVC) | |
Starting torque | AM: 0.25Hz/150% (SVC) SM: 2.5Hz/150% (SVC) 0Hz/200% (FVC) | |
Overload capacity | Able to run at 150% of the rated current for 1 minute, 180% of the rated current for 10 seconds, and 200% of the rated current for 1 second. | |
Running control performance | Frequency setting method | Settings can be implemented through digital, analog, pulse frequency, multi-step speed running, simple PLC, PID, Modbus communication, PROFIBUS communication and so on. Settings can be combined and the setting channels can be switched. |
Automatic voltage regulation (AVR) | The output voltage can be kept constant although the grid voltage changes. | |
Fault protection | More than 30 protection functions, such as protection against overcurrent, overvoltage, undervoltage, overtemperature, phase loss, and overload. | |
Start after speed tracking | Enables smooth startup of a rotating motor. Note: Applicable to models ≥ 4kW | |
Transient power loss ride-through | In the event of a transient power drop, the VFD continues to operate using the regenerated energy, ensuring no downtime. | |
Dual motor switching | Supports switching between two sets of motor parameters. | |
Peripheral interface | Terminal analog input resolution | No more than 20mV |
Terminal digital input resolution | No more than 2ms | |
Analog input | Two inputs; AI1: 0–10V/0–20mA; AI2: -10–+10V | |
Analog output | One output; AO1: 0–10V/0–20mA | |
Digital input | Four regular inputs; max. frequency: 1kHz; internal impedance: 3.3kΩ Two high-speed inputs; max. frequency: 50kHz; supporting quadrature encoder input; with speed measurement function | |
Digital output | One high-speed pulse output; max. frequency: 50kHz One Y terminal open collector output | |
Relay output | Two programmable relay outputs RO1A: NO; RO1B: NC; RO1C: common RO2A: NO; RO2B: NC; RO2C: common Contact capacity: 3A/AC250V, 1A/DC30V | |
Expansion interfaces | Three expansion interfaces: SLOT1, SLOT2, and SLOT3 (available on control boards for VFDs 7.5kW and above). Support PG cards, programmable expansion cards, communication cards, I/O cards, and other cards. | |
Other | Mounting method | Supports wall mounting, floor mounting, and flange mounting. |
Temperature of running environment | -10°C–+50°C. Derating is required when the ambient temperature exceeds 40°C. | |
Ingress protection (IP) rating | IP20 | |
Pollution degree | Degree 2 | |
Cooling method | Forced air cooling | |
Braking unit | 380V 11kW–75kW (inclusive) models: Standard (built-in) 660V models: Optional (external) | |
EMC filter | All 380V models can meet IEC/EN 61800-3 C3 requirements for conducted emissions. Optional external filters can be used to meet the IEC61800-3 C2 requirements for conducted emissions. Note: Comply with the EMC specifications required in the manual appendix. Motors and motor cables shall be selected according to the technical requirements specified in the manual appendix. | |