Item | Specifications | |
Power input | Input voltage (V) | AC 3PH 380V (-15%)–440V (+10%) Rated voltage: 380V |
| AC 3PH 520V (-15%)–690V (+10%) Rated voltage: 660V | ||
Input frequency (Hz) | 50Hz or 60Hz; allowed range: 47–63Hz | |
Input power factor | 30–110kW≥0.9 | |
Power output | Output voltage (V) | 0–input voltage |
Output frequency (Hz) | 0–150Hz | |
Technical control performance | Control mode | Space voltage vector control mode |
| SVC mode | ||
| FVC mode | ||
Motor type | Asynchronous motor (AM) and permanent magnet synchronous motor (SM) | |
Speed ratio | 1:200 (SVC) | |
| 1:1000 (FVC) | ||
Speed control accuracy | ±0.2% (SVC) | |
| ±0.02% (FVC) | ||
Speed fluctuation | ±0.3% (SVC) | |
| ±0.02% (FVC) | ||
Torque response | <20ms (SVC) | |
| <10ms (FVC) | ||
Torque control accuracy | 10% (SVC) | |
| 5% (FVC) | ||
Starting torque | AM: 0.25Hz/150% (SVC) | |
| SM: 2.5Hz/150% (SVC) | ||
| 0Hz/200% (FVC) | ||
Overload capacity | Able to run at 150% of the rated current for 1 minute, 180% of the rated current for 10 seconds, and 200% of the rated current for 1 second. | |
Braking capability | 100% braking power for continuous operation, 120% braking power for 1 minute, and 160% braking power for 10 seconds. | |
Running control performance | Frequency setting method | Settings can be implemented through digital, analog, pulse frequency, multi-step speed running, simple PLC, PID, Modbus communication, PROFIBUS communication and so on. Settings can be combined and the setting channels can be switched. |
Automatic voltage regulation (AVR) | The output voltage can be kept constant although the grid voltage changes. | |
Fault protection | More than 30 protection functions, such as protection against overcurrent, overvoltage, undervoltage, overtemperature, phase loss, and overload. | |
Dedicated functions | Braking protection | Models 30–110kW support protection against braking resistor short circuit, braking unit short circuit, and PB-PE short circuit. |
Brake control | Dedicated hoisting brake logic, integrated with torque verification, brake feedback, zero position detection, restart after braking functions, which meet the industrial VFD standards for crane applications. | |
Conical rotor motor control | Boosts magnetic flux during startup to ensure brake release, and reduces flux during stop to achieve brake closing. | |
Light load speed boost | In closed-loop mode, the speed can be boosted and limited at constant power status, and the speed is limited in stepped way. | |
| In open-loop mode, if the simplified speed boost way is used, the speed boosts to the set frequency in light load status; if the speed is boosted or limited in constant power status, the speed is limited in stepped way. | ||
Zero servo | In closed-loop mode, if the VFD detects load downward slip, the VFD automatically enters the zero servo state and outputs a brake failure alarm. When a level-2 fault occurs, if load downward slip occurs, the VFD automatically resets the fault, enters the zero servo state, and outputs a brake failure alarm. | |
Long/cross travel anti-sway and sway reducing | Anti-sway: Requires an encoder on the hoisting mechanism. The hoisting mechanism and the long and cross travel VFDs are connected via AI or HDI, or both are equipped with CAN master-slave cards for communication. This allows the long and cross travel VFDs to obtain the real-time height value from the hoisting mechanism VFD. Combined with the built-in luffing anti-sway algorithm, the VFD outputs the reference frequency and acceleration/deceleration time. The long and cross travel VFDs then accelerate or decelerate based on the start/stop commands and the reference frequency, eliminating sway when the VFD reaches a steady state or when stopping. | |
| Sway reducing: Does not require real-time height data. Based on the built-in luffing anti-sway algorithm, the VFD can operate according to the set acceleration/deceleration time, reducing sway when the VFD reaches a steady state or when stopping. | ||
Tower crane slewing without using an eddy current controller | Built-in curves for tower crane slewing without using eddy current control help to adjust the ACC in real time so that the torque is steady, which can suppress boom rebound and vibration when the boom pauses or stops. | |
Wind resistance of tower crane slewing | To address the issue where slewing speeds fail to reach the reference speed in windy environments, the VFD features a built-in slewing wind resistance algorithm to overcome the impact of wind on slewing operations. | |
Slack rope protection (closed-loop mode only) | Upward slack rope protection: If a slack rope state is detected, the speed is limited; the speed limit is released upon timeout or when the load is lifted. | |
| Downward slack rope protection: If a slack rope state is detected, the VFD reports a fault or an alarm. | ||
Upward/downward limit position | The function is used to limit the crane to run within the specified range. The VFD enables emergency stop and reports an alarm once the range is exceeded. | |
Upward/downward DEC limit position | When the deceleration signal is valid, the running speed of the crane is limited once the crane runs within the slow speed area. | |
| Single direction limit: For example, in the upward slow speed area, the speed limit applies only to upward travel. | ||
Load position | In closed-loop mode, the encoder is used to measure the load position. | |
Master/slave control | Master/slave power balance and speed synchronization. | |
Hoisting application macro | Including lifting, horizontal moving, construction elevator, tower crane slewing, and user-defined application macros. | |
Lifting and horizontal moving switchover | Three groups of motor parameters, control modes, and application macros can be switched. | |
Frequency decrease with voltage | When the bus voltage is continuously low, the reference frequency is decreased to keep the normal output torque of VFD. | |
Low-voltage protection | When the bus voltage decreases transiently or the VFD quickly stops due to power outage, the function is used to ensure the hook does not slip. The low voltage protection function is automatically disabled once the bus voltage restores to the normal state. | |
Low-speed run protection | The VFD reports the low-speed run protection fault when the low-speed run time exceeds the allowed time. This prevents the axial cooling motor from being damaged due to overheating caused by long-time running. | |
Overload protection | In closed-loop mode, when overload occurs, upward lifting is restricted. | |
Eddy current control | The HDO outputs PWM waves to directly control eddy current. | |
Brake feedback (FB) | When the brake control signal is inconsistent with the brake feedback signal, the VFD handles the inconsistency according to the brake status to ensure safety. | |
Zero position detection | The zero position signal and running signal are mutually exclusive. | |
Torque verification | The VFD verifies the current or torque before brake release. The VFD performs brake release when the verification succeeds, and the VFD reports the verification fault when the verification fails. | |
One key open/closed loop switchover | The closed-loop control mode can be switched to the open-loop control mode through terminals. When the encoder is faulty, the open-loop control mode can be used. The switchover takes effect only in stopped state but not in running state. | |
Jogging | After receiving a jogging command, the VFD can automatically start, run, and stop at the preset running frequency and time according to the settings. During the process, the brake can be normally opened or closed under the control of VFD, ensuring the stability without hook slip or exception when the crane starts or stops. | |
Smooth lifting | In high-speed lifting mode, the high speed is limited at the moment of steel rope straightening, reducing the impact caused by the sudden load to the crane at the lifting start. | |
Set frequency exception protection | If the set frequency is lower than the threshold after the brake is opened, the VFD reports the set frequency exception, which prevents slip caused by insufficient force at low speed. | |
Motor overheating protection | An I/O expansion card can receive the input from a motor temperature sensor (PT100, PT1000, or PTC). At the same time, the AI analog input can also receive signals from a motor temperature sensor (PT100, PT1000, KTY84, or various PTC models) for motor overheating protection. | |
Peripheral interface | Terminal analog input resolution | No more than 20mV |
Terminal digital input resolution | No more than 2ms | |
Analog input | Two inputs; AI1: 0–10V/0–20mA; AI2: -10–+10V | |
Analog output | One input; AO1: 0–10V/0–20mA | |
Digital input | Four regular inputs; max. frequency: 1kHz; internal impedance: 3.3kΩ | |
| Two high-speed inputs; max. frequency: 50kHz; supporting quadrature encoder input; with speed measurement function | ||
Digital output | One high-speed pulse output; max. frequency: 50kHz | |
| One Y terminal open collector output | ||
Relay output | Two programmable relay outputs | |
| RO1A: NO; RO1B: NC; RO1C: common | ||
| RO2A: NO; RO2B: NC; RO2C: common | ||
| Contact capacity: 3A/AC250V, 1A/DC30V | ||
Expansion interfaces | SLOT1, SLOT2, and SLOT3 | |
| Supports PG cards, programmable expansion cards, communication cards, I/O cards, and other cards. | ||
| Note: | ||
| 1. You can install optional expansion cards for 1.5–5.5kW VFD models and you are recommended to install them in slot 2. | ||
| 2. I/O expansion card 2 has been installed in slot 3 for 7.5kW and higher VFD models as standard configuration. | ||
I/O expansion card 2 | Relay output | Two programmable relay outputs; contact capacity: 3A/250VAC, 1A/30VDC |
| RO3A: NO; RO3C: common; RO4A: NO; RO4C: common | ||
Digital input | Three regular inputs | |
| Internal impedance: 6.6kΩ | ||
| Max. input frequency: 1kHz | ||
| Supporting the internal power 24V | ||
| Supporting the voltage input of external power (-20%) 24–48VDC (+10%) and (-10%) 24–48VAC (+10%) | ||
| Bidirectional input terminals, simultaneously supporting NPN and PNP connection methods | ||
| One channel supports PTC input, while PTC acts at 2.5kΩ, and supports the input of only dry contacts sharing COM. | ||
PT100 input | Independent PT100 and PT1000 input: | |
| 1. Resolution: 1°C | ||
| 2. Range: -20°C–150°C | ||
| 3. Detection precision: 3°C | ||
PT100 input | 4. Supporting offline protection | |
Other | Mounting method | Supports wall mounting, floor mounting, and flange mounting. |
Temperature of running environment | -10°C–+50°C. Derating is required when the ambient temperature exceeds 40°C. | |
Ingress protection (IP) rating | IP20 | |
Pollution degree | Degree 2 | |
Cooling method | Forced air cooling | |
DC reactor | 380V 18.5–110kW models: Standard (built-in) 380V 132kW and above models, and 660V models: Optional (external) | |
Braking unit | 380V 110kW and below models: Standard (built-in) 660V models: Optional (external) | |
EMC filter | Optional built-in C3 filter. | |
| If a C3 filter is required, connect the jumper J10. After the C3 filter is configured, the VFD can meet IEC61800-3 C3 requirements. | ||
| Optional external filters can be used to meet the IEC61800-3 C2 requirements. | ||
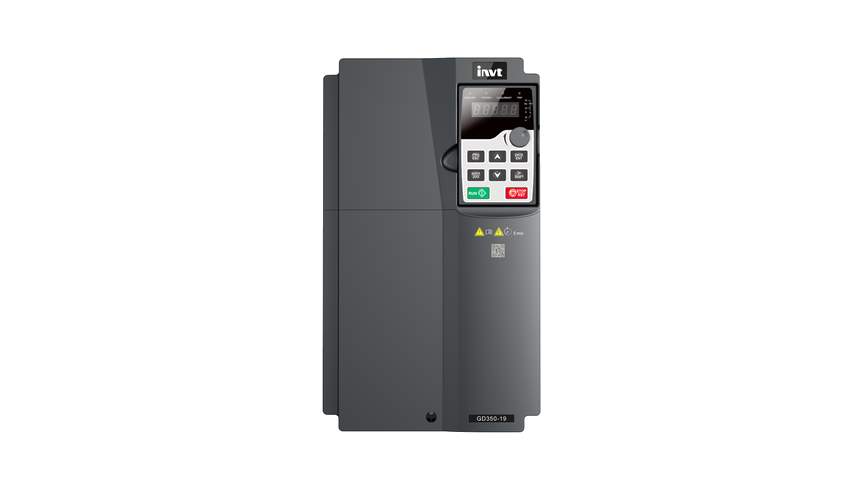
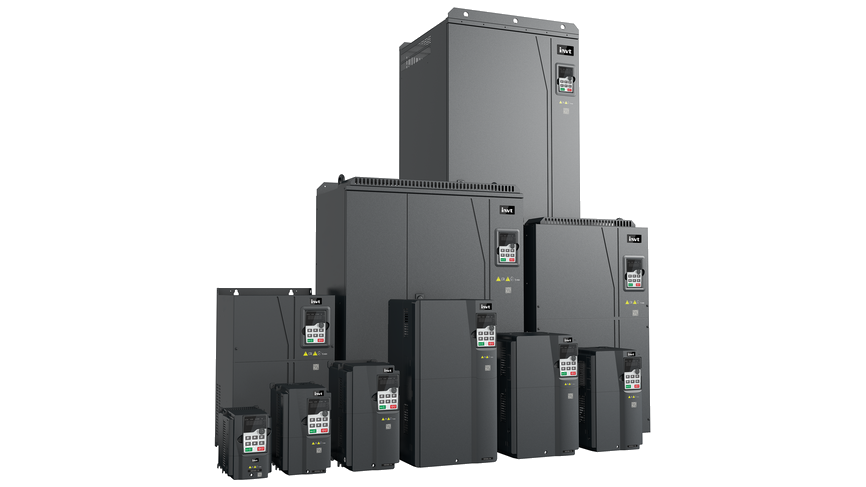
GD350-19 Series High-Performance VFD for Crane
The GD350-19 series high-performance Variable Frequency Drive (VFD) for cranes is a new-generation product from INVT, developed based on over a decade of experience in the crane industry and advanced control theories. Featuring excellent control performance, comprehensive safety protections, strong expansion capabilities, and user-friendliness, it is widely applicable to various types of lifting equipment, including port machinery, factory cranes, construction machinery, and mining machinery.


 Images
Features

 Travel limit protection: Integrated upper/lower limit and deceleration limit functions to restrict crane operation within a designated range, ensuring safety while optimizing stop modes and improving equipment efficiency.Slack rope protection: Prevents accidents during high-speed hoisting when the rope is slack, malfunctions in acceleration, or rope failure.Smooth hoisting: Automatically decelerates when the hook lifts a load during high-speed operation, ensuring smooth hoisting and minimizing impact on the crane.Zero servo: Locks the motor at zero speed, maintaining zero-speed hold even under external force in forward/reverse directions. Even in case of brake failure, the system can drive the motor to maintain full-load holding or controlled slow lowering, ensuring operational safety. Anti-snag protection: Emergency stop in case of unexpected contact with other objects during hoisting, improving safety and efficiency.Safe Torque Off (STO/SIL2): Cuts off torque output when the motor stops, preventing accidental startup while allowing continuous system monitoring for quick recovery. Braking short-circuit protection: Protection against braking resistor short circuits with ultra-high braking torque.Dedicated brake logic: Integrated with torque verification to ensure that the brake is released only after sufficient torque is established, preventing unintended load slip. The system also supports brake release selection based on startup direction and forward/reverse switching, offering high adaptability to various startup requirements.High torque at low frequency: Feedback vector control (FVC): 0Hz/200% (rated torque); space voltage vector control: 0.5Hz/150% (rated torque).Excellent load adaptability: Hoisting-specific control algorithm enables torque output to adapt to different loads, ensuring smooth performance under both loaded and unloaded conditions.Crane-specific application macros: Pre-configured macros for common hoisting applications enable one-key parameter setup (refer to the user manual for details). Custom macros supported.One-key open/closed-loop switching: In the event of encoder failure, you can quickly switch to open-loop control and switch macros accordingly without affecting equipment operation (not supported during runtime).Multiple control modes: Supports various speed reference methods, including operating lever, graded operating lever, motorized potentiometer, communication, remote control, and graded remote control, adaptable to diverse crane applications. Tower crane slewing without using eddy current control: Eliminates eddy current during tower crane slewing, enabling quick stop via reverse braking, fast switching between directions, and low-speed jogging positioning.Tower crane slewing control: Built-in dedicated algorithm ensures stable start/stop, supporting reverse braking and low-speed hook following for higher efficiency and easier operation.
5. Cost-effective and efficient3-group motor switching: Supports time-based control of multiple motors to reduce costs. Macro parameters switch with motor switching, eliminating repetitive parameter configuration—even during master-slave switching.Conical rotor motor control: Flux regulation tailored for conical rotor motors enables fast brake release/closing and simplified commissioning, ensuring equipment safety.Double-winding motor control: Reliable solution for dual-winding motor control.Outer-rotor motor control: Built-in mature and reliable control algorithm supports non-integer gear ratios between motor and resolver pole pairs.Anti-sway function: Sensorless anti-sway control algorithm suitable for various crane types, achieving simple commissioning and excellent adaptability.
Standard anti-sway: Effectively suppresses load sway during travel, improving efficiency.
High-efficiency sway reducing: Significantly reduces load sway during travel, enhancing efficiency.Light-load speed boost: Supports constant power and stepped speed limit modes for optimal speed matching based on load, shortening crane cycles and improving operational efficiency.Positioning stop: In closed-loop mode, the VFD supports precise stop control for long travel, cross travel, and lifting, improving precision and efficiency.Master-slave control: Supports power balance and speed synchronization. Power balance ensures uniform output across motors for rigidly coupled multi-motor systems. Speed synchronization ensures synchronized lifting among hoisting mechanisms. Supports one-master-multiple-slave configuration and flexible master-slave switching.Rich expansion card options: Supports up to 3 expansion cards (I/O expansion card, communication card, PG card) to accommodate different application scenarios (models ≤5.5KW support 2 cards).
Specifications
Downloads
 Load More
Have questions or need support?
Our professional team is here to help.

Repair Progress Tracking | Identity Verification
To protect your repair information, please verify using the mobile number reserved on the service order.

Contact INVT
Get in touch with INVT. Our team will get back to you shortly.
-
Industrial Automation
-
Network Power
-
PV & ESS
-
e-Mobility